|
|
| UnionEnvelope (std::vector< std::shared_ptr< Envelope > > members) |
| |
| bool | is_outside (const std::array< Eigen::Vector3d, 3 > &tris) const override |
| |
| bool | is_outside (const Eigen::Vector3d &pts) const override |
| |
| bool | is_outside (const std::array< Eigen::Vector2d, 2 > &edge) const override |
| |
| bool | is_outside (const Eigen::Vector2d &pts) const override |
| |
| | Envelope (bool exact=true) |
| |
| void | set_max_threads (int n) |
| | How many threads one triangle query may use. 1, the default: every sample is checked on the calling thread.
|
| |
|
virtual void | init (const std::vector< Eigen::Vector3d > &m_ver, const std::vector< Eigen::Vector3i > &m_faces, const double) |
| |
|
void | init (const std::vector< Eigen::Vector3d > &m_ver, const std::vector< Eigen::Vector2i > &m_edges, const double) |
| |
|
void | init (const std::vector< Eigen::Vector2d > &m_ver, const std::vector< Eigen::Vector2i > &m_edges, const double) |
| |
| void | init (const Eigen::MatrixXd &V, const Eigen::MatrixXi &F, const double eps) |
| | Same, from Eigen matrices, dispatching on the column counts.
|
| |
|
bool | is_outside (const std::array< Eigen::Vector3d, 2 > &edge) const |
| |
|
double | nearest_point (const Eigen::Vector3d &pts, Eigen::Vector3d &result) const |
| |
|
double | nearest_point (const Eigen::Vector2d &pts, Eigen::Vector2d &result) const |
| |
| double | nearest_point_feature (const Eigen::Vector2d &p, Eigen::Vector2d &result, bool &on_corner, Eigen::Vector2d &seg_normal, int &feature_id) const |
| |
| double | nearest_point_feature (const Eigen::Vector3d &p, Eigen::Vector3d &result, int &feature_dim, Eigen::Vector3d &dir, long long &feature_id) const |
| |
|
bool | initialized () |
| |
|
Kind | kind () const |
| |
|
double | squared_distance (const Eigen::Vector3d &p) const |
| |
|
double | squared_distance (const Eigen::Vector2d &p) const |
| |
| void | primitives_in_box (const Eigen::Vector3d &lo, const Eigen::Vector3d &hi, std::vector< int64_t > &ids) const |
| | The ids of every primitive whose bounding box meets the closed box [lo, hi], ascending, each once.
|
| |
|
void | primitives_in_box (const Eigen::Vector2d &lo, const Eigen::Vector2d &hi, std::vector< int64_t > &ids) const |
| | The 2D counterpart, for Edges2d: the same tree, which holds the 2D input lifted to z = 0.
|
| |
| double | primitive_distance (int64_t id, const Eigen::Vector3d &p, Eigen::Vector3d *grad=nullptr, Eigen::Matrix3d *hess=nullptr) const |
| | The distance d from p to primitive id alone, with its gradient and Hessian when asked for (nullptr = not wanted).
|
| |
| double | primitive_distance (int64_t id, const Eigen::Vector2d &p, Eigen::Vector2d *grad=nullptr, Eigen::Matrix2d *hess=nullptr) const |
| |
| double | primitive_triangle_distance (int64_t id, const std::array< Eigen::Vector3d, 3 > &tri) const |
| | The distance between the triangle tri and primitive id alone.
|
| |
| double | primitive_segment_distance (int64_t id, const std::array< Eigen::Vector2d, 2 > &seg) const |
| | The 2D counterpart, for Edges2d: the distance between the segment seg and primitive id alone – a 2D front edge where the 3D query takes a front face.
|
| |
Inside means inside any member: the tube union. Assigned to the inherited m_envelope, so the shared engine's "may this surface vertex land on a non-surface position" point check keeps its semantics with no changes there.
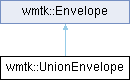
 Public Member Functions inherited from wmtk::Envelope